Nikola Kang | 康雷I received my M.S. from Peking University, advised by Prof. Yunfeng Xiao. I received my B.S. in Computer Science from Beijing Jiaotong University. My research focuses on scalable embodied learning, with the goal of enabling robots to acquire general-purpose skills through large-scale interaction. I investigate the complete embodied learning pipeline, including realistic simulation environments, scalable interaction data generation, vision-language-action (VLA) learning, and systematic evaluation. Through this line of research, I seek to understand how better environments, richer data, and more effective learning algorithms can jointly improve the capability and generalization of embodied agents in complex physical worlds. |
|
News
- 2026: UseAppliance is accepted to ACMMM 2026. Project page is available here.
- Jun 2026: Our paper JoyAI-Sim is available on arXiv.
- 2026: RealAppliance is accepted to CVPR 2026 as a Highlight.
- 2026: NavSpace is accepted to ICRA 2026.
Selected Publications
|
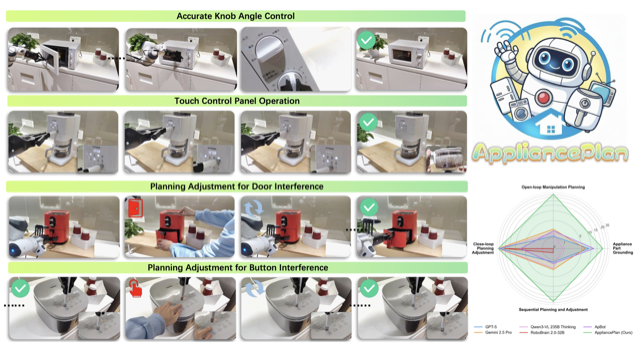
Scaling Manual-Grounded Appliance Manipulation with Data Synthesis and Unified Planning
Yuxing Long*, Lei Kang*, Ziyan Yu, Yuzheng Gao, Bin Cheng, Jiyao Zhang, Xiaoqi Li, Haolin Yang, Dongjiang Li, Hui Shen, Hao Dong ACMMM 2026 Paper / Project / Code (soon) ACMMM Appliance Manipulation Data Synthesis VLA Planning MAGE synthesizes grounding, planning, and closed-loop recovery data from manuals; UseAppliance trains AppliancePlan, a unified 7B planner that leads RealAppliance-Bench and transfers to real robots. |
|
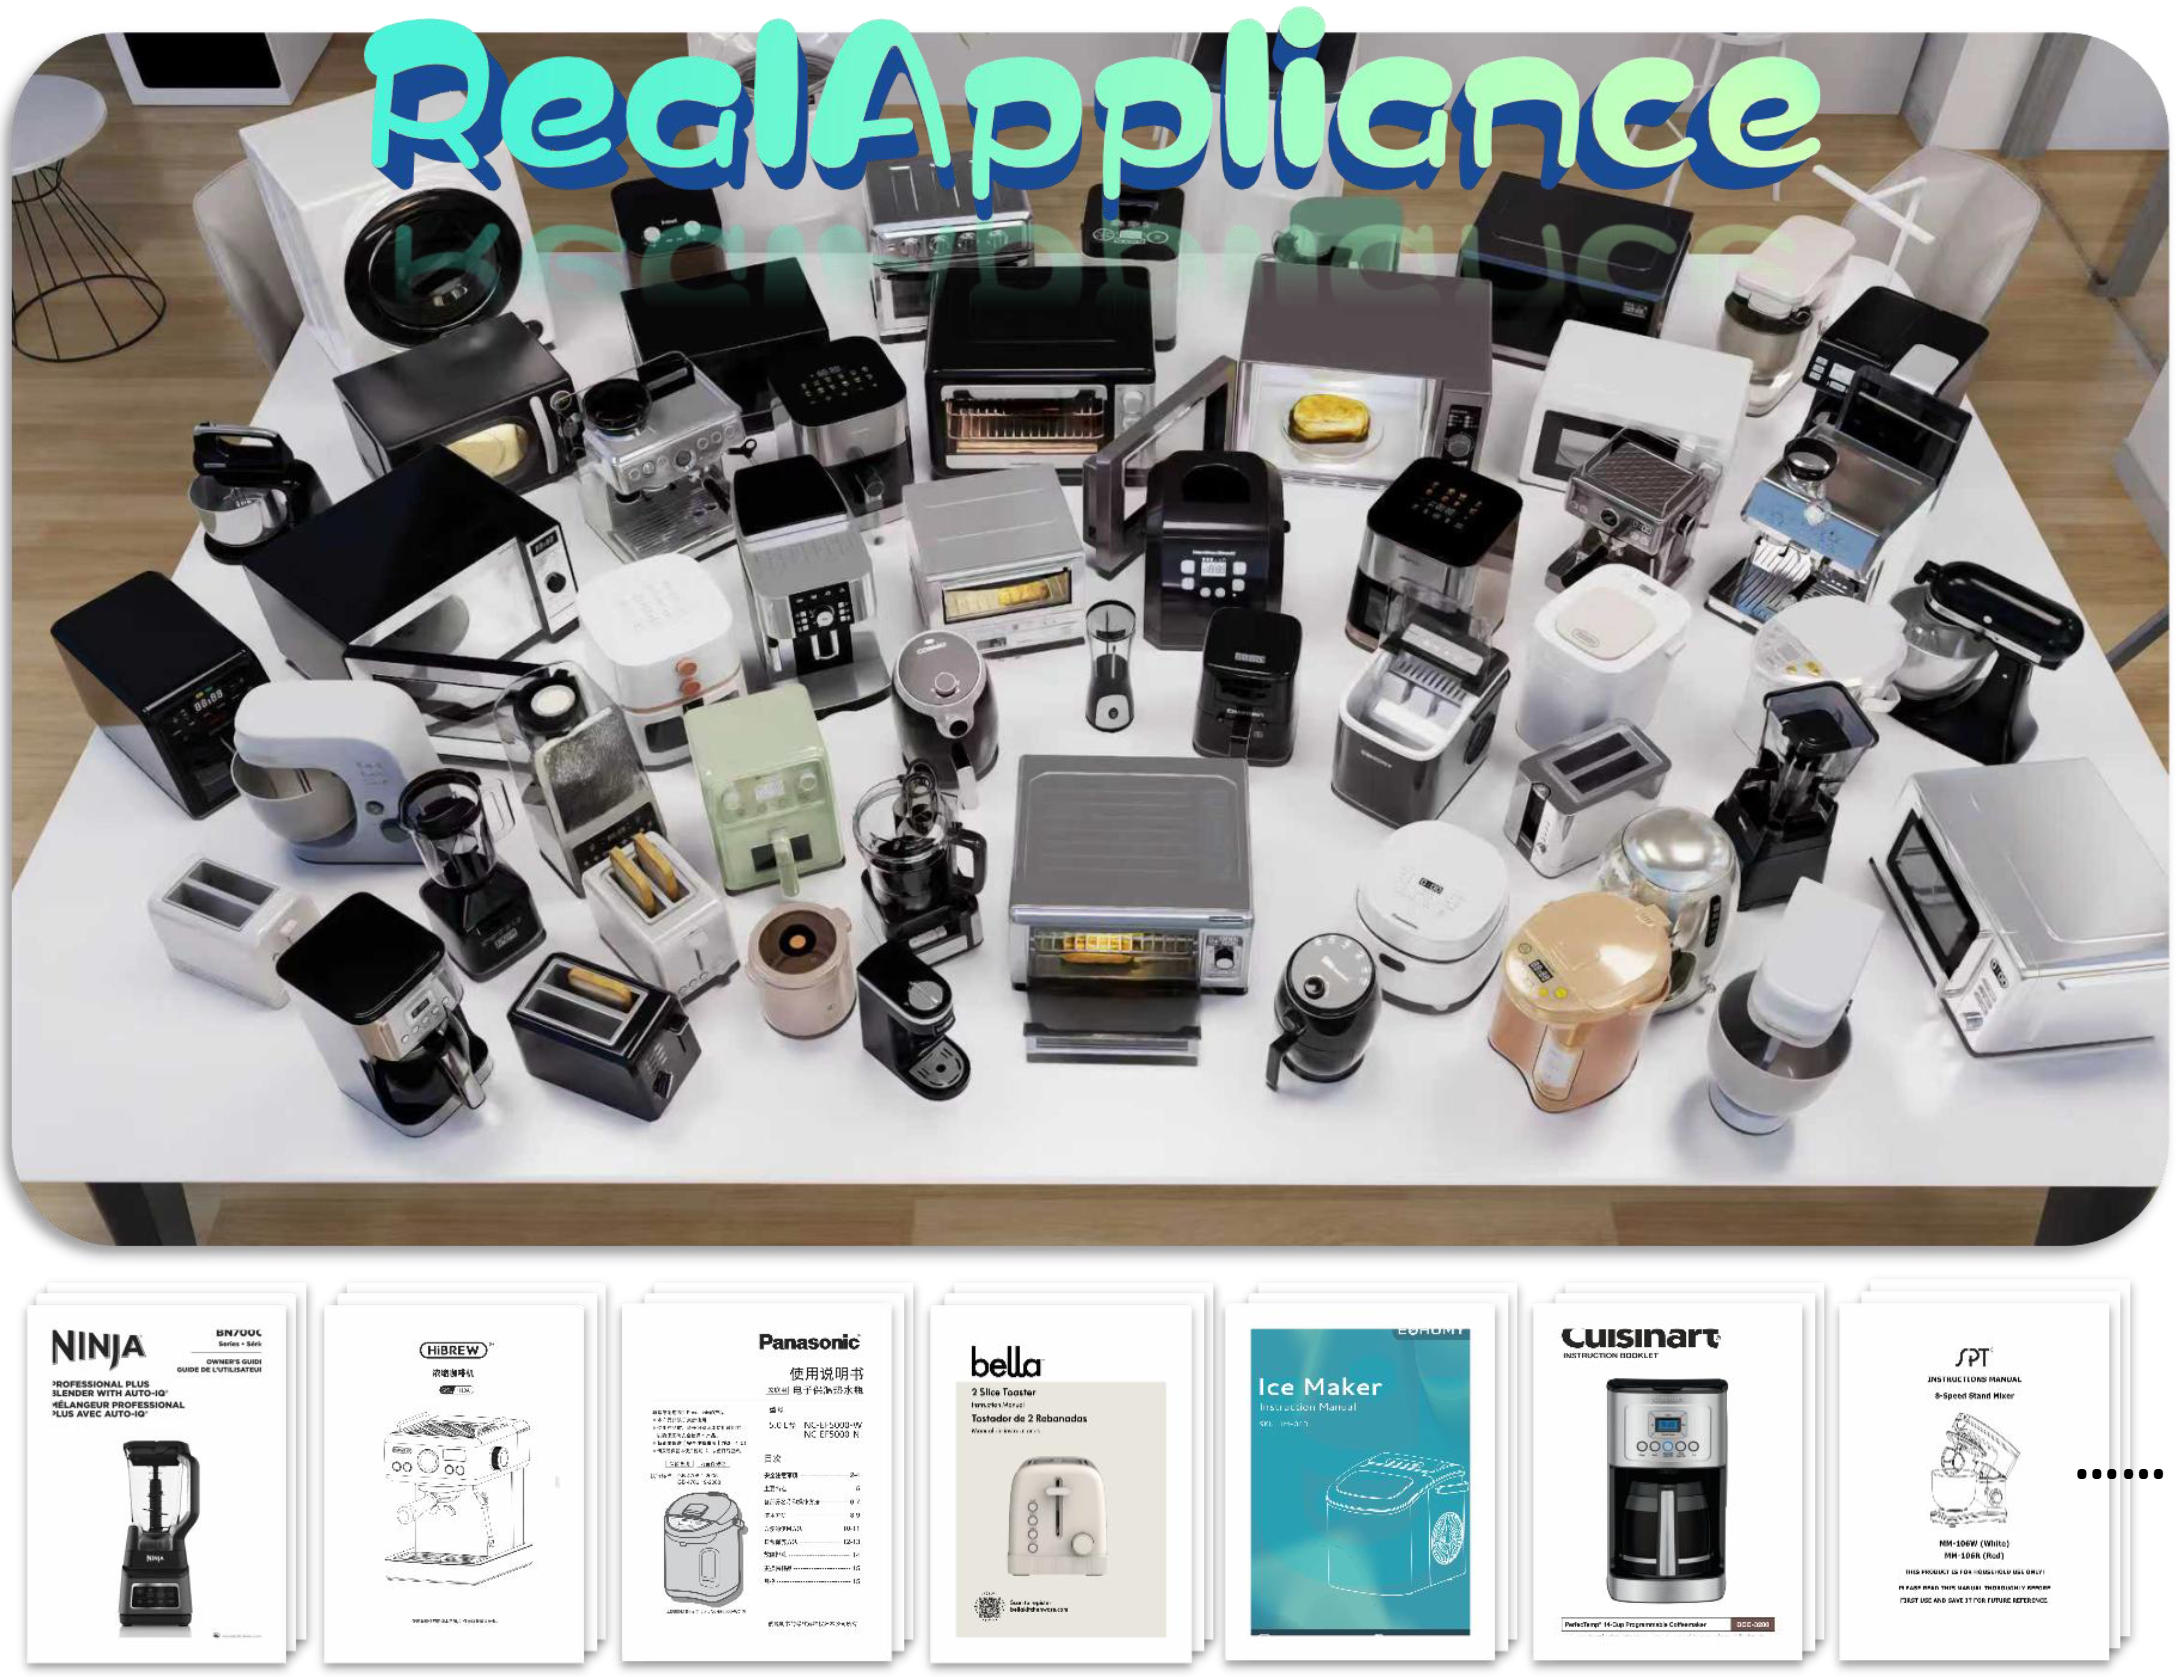
RealAppliance: Let High-fidelity Appliance Assets Controllable and Workable as Aligned Real Manuals
Yuzheng Gao*, Yuxing Long*, Lei Kang, Yuchong Guo, Ziyan Yu, Shangqing Mao, Jiyao Zhang, Ruihai Wu, Dongjiang Li, Hui Shen, Hao Dong CVPR 2026, Highlight Paper / Project / Code CVPR Highlight Embodied AI Appliance Digital Twins Simulation High-fidelity controllable appliance digital twins aligned with real manuals for embodied interaction, instruction following, state-aware operation, and realistic appliance evaluation. |
|
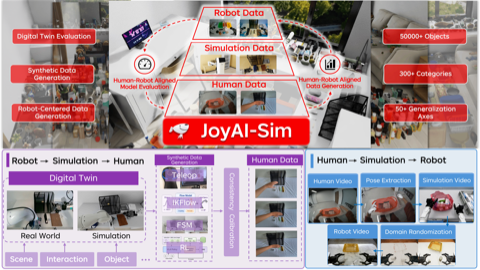
JoyAI-Sim: A Simulation-Enabled Interconversion Toolchain for the Embodied Data Pyramid
Peidong Liu, Yongce Liu, Songyan Guo, Fuyuan Ma, Zhihao Yuan, Ao Li, ..., Lei Kang, Junwu Xiong, Jiawei Li, Hui Shen, Yicheng Gong, Nan Duan, Liang Lin arXiv, 2026 Paper / Project Embodied Simulation Robot Data Digital Twin Evaluation A simulation-enabled interconversion toolchain for human-robot aligned model evaluation and data generation, connecting robot trials, simulation, and human demonstrations through reusable cloud-based infrastructure. |
|
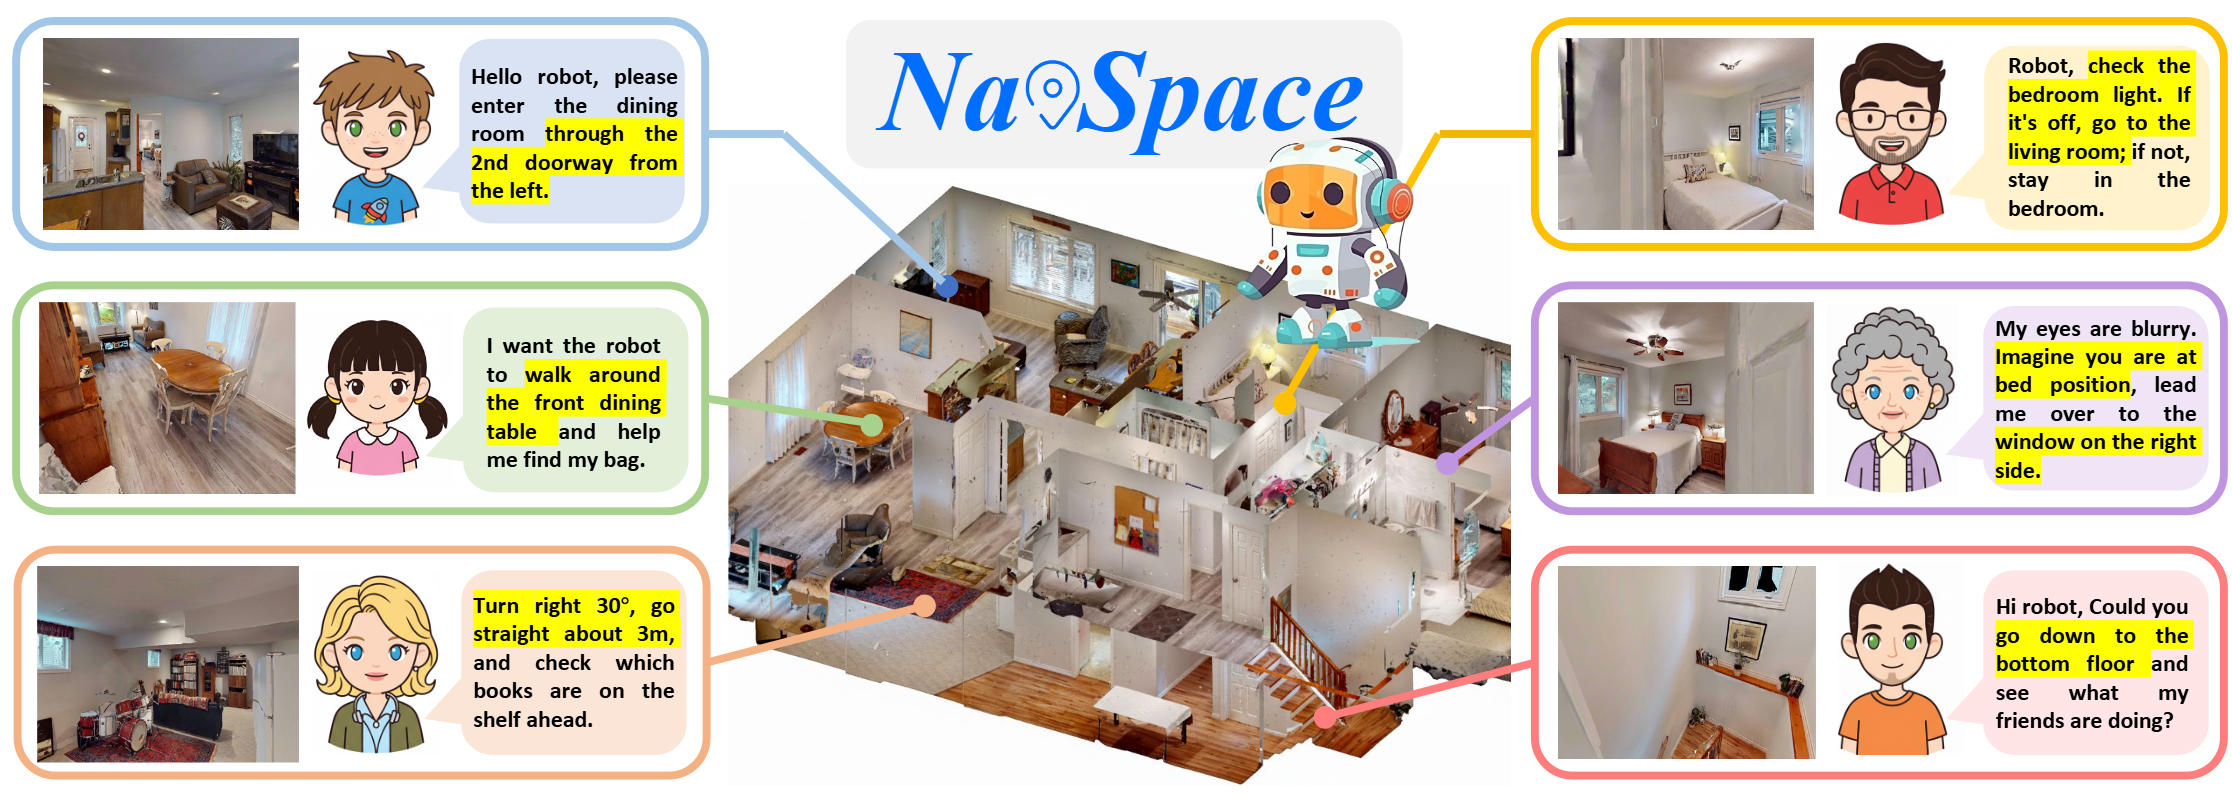
NavSpace: How Navigation Agents Follow Spatial Intelligence Instructions
Haolin Yang*, Yuxing Long*, Zhuoyuan Yu, Zihan Yang, Minghan Wang, Jiapeng Xu, Yihan Wang, Ziyan Yu, Wenzhe Cai, Lei Kang, Hao Dong ICRA 2026 Paper / Project ICRA Navigation Spatial Intelligence Embodied Agents A benchmark and model for evaluating how navigation agents understand and follow spatial intelligence instructions. |
Internships
- Jul 2025 - Present, JD Technology
- Apr 2025 - Jul 2025, Center on Frontiers of Computing Studies, Peking University
Services
More information will be updated soon.
Selected Awards and Honors
- Siyuan Times Special Scholarship of Beijing Jiaotong University, 2019
- First-Class Scholarship, 2019, 2020
- Merit Student of Beijing Jiaotong University, 2019, 2020
Last updated: September 2026.